> For the complete documentation index, see [llms.txt](https://docs.engagevr.io/developer/llms.txt). Markdown versions of documentation pages are available by appending `.md` to page URLs; this page is available as [Markdown](https://docs.engagevr.io/developer/afx/node-dictionary/unity/transform/get.md).

# Get

## Get Tracked Rotation

Measures the rotation around a given axis since the first activation of the node.

**Inputs:**

<table><thead><tr><th width="155">Name</th><th width="165">Type</th><th>Description</th></tr></thead><tbody><tr><td>Enter</td><td>Flow</td><td>Initiating flow.</td></tr><tr><td>Transform In</td><td>Transform</td><td>Reference to a transform.</td></tr></tbody></table>

**Parameters:**

<table><thead><tr><th width="155">Name</th><th width="165">Type</th><th>Description</th></tr></thead><tbody><tr><td>Axis</td><td>List</td><td>The X, Y, or Z axis to track rotation around.</td></tr></tbody></table>

**Outputs:**

<table><thead><tr><th width="154">Name</th><th width="166">Type</th><th>Description</th></tr></thead><tbody><tr><td>Exit</td><td>Flow</td><td>Continuation of the initiating flow.</td></tr><tr><td>Rotation Degree Count</td><td>Float</td><td>The number of degrees that the transform has rotated around the given axis since the first activation of the node.<br><br>On first activation, <code>Rotation Degree Count</code> is 0. On all subsequent activations, <code>Rotation Degree Count</code> is the change since first activation.</td></tr></tbody></table>

**Example:**

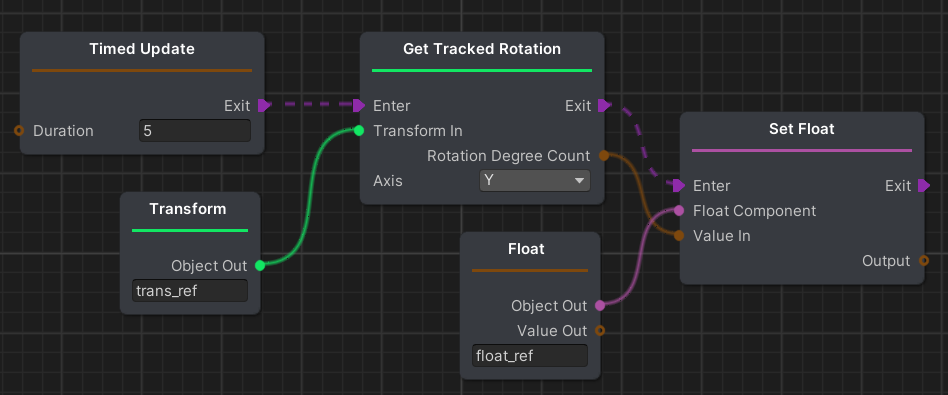
The following graph updates a float component every 5 seconds with the number of degrees that the transform has rotated around the Y axis.

<figure><img src="https://2640392766-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2F5yxYHsXtlAaoMUrDWhLm%2Fuploads%2Fgit-blob-41ebd9cedc7ac31cafe2fcb3c6146ac5c0261c36%2Fafx_get_tracked_ex.png?alt=media" alt=""><figcaption><p>Example graph to track a transform's rotation every 5 seconds</p></figcaption></figure>

## Get Euler Angles

Extract rotation from the transform in Euler angles.

**Inputs:**

<table><thead><tr><th width="155">Name</th><th width="169">Type</th><th>Description</th></tr></thead><tbody><tr><td>Transform In</td><td>Transform</td><td>Reference to a transform.</td></tr><tr><td>Local</td><td>Boolean [editable]</td><td>If true, the output is the object's local rotation. If false, the output is the object's rotation relative to world space.</td></tr></tbody></table>

**Outputs:**

<table><thead><tr><th width="154">Name</th><th width="170">Type</th><th>Description</th></tr></thead><tbody><tr><td>Euler Angles Out</td><td>Vector3</td><td>Rotation in Euler angles.</td></tr></tbody></table>

## Get Local Position

Extract a local position from a transform.

**Inputs:**

<table><thead><tr><th width="155">Name</th><th width="165">Type</th><th>Description</th></tr></thead><tbody><tr><td>Transform</td><td>Transform</td><td>Reference to a transform.</td></tr></tbody></table>

**Outputs:**

<table><thead><tr><th width="154">Name</th><th width="166">Type</th><th>Description</th></tr></thead><tbody><tr><td>Local Position</td><td>Vector3</td><td>The local position of the transform.</td></tr></tbody></table>

## Get Local Scale

Extract a local scale from a transform.

**Inputs:**

<table><thead><tr><th width="155">Name</th><th width="165">Type</th><th>Description</th></tr></thead><tbody><tr><td>Transform</td><td>Transform</td><td>Reference to a transform.</td></tr></tbody></table>

**Outputs:**

<table><thead><tr><th width="154">Name</th><th width="166">Type</th><th>Description</th></tr></thead><tbody><tr><td>Local Scale</td><td>Vector3</td><td>The local scale of the transform.</td></tr></tbody></table>

## Get Position

Extract a world space position from a transform.

**Inputs:**

<table><thead><tr><th width="155">Name</th><th width="165">Type</th><th>Description</th></tr></thead><tbody><tr><td>Transform</td><td>Transform</td><td>Reference to a transform.</td></tr></tbody></table>

**Outputs:**

<table><thead><tr><th width="154">Name</th><th width="166">Type</th><th>Description</th></tr></thead><tbody><tr><td>Output</td><td>Vector3</td><td>World space position.</td></tr></tbody></table>

## Get Rotation

Extract a world space rotation from a transform.

**Inputs:**

<table><thead><tr><th width="155">Name</th><th width="165">Type</th><th>Description</th></tr></thead><tbody><tr><td>Transform In</td><td>Transform</td><td>Reference to a transform.</td></tr></tbody></table>

**Outputs:**

<table><thead><tr><th width="154">Name</th><th width="166">Type</th><th>Description</th></tr></thead><tbody><tr><td>Rotation Out</td><td>Quaternion</td><td>World space rotation.</td></tr></tbody></table>
